* denotes equal contribution.
2026
-
See to Reach, Feel to Grasp: Learning A Blind Grasp Reflex for Anthropomorphic Robotic HandsPreprint
-
Steerable and Reactive Grasping Through Modular Design with a Three-Point InterfacePreprint
-
-
POIL: Point-based One-Shot Imitation Learning with Stable Dynamical SystemsPreprint
-
-
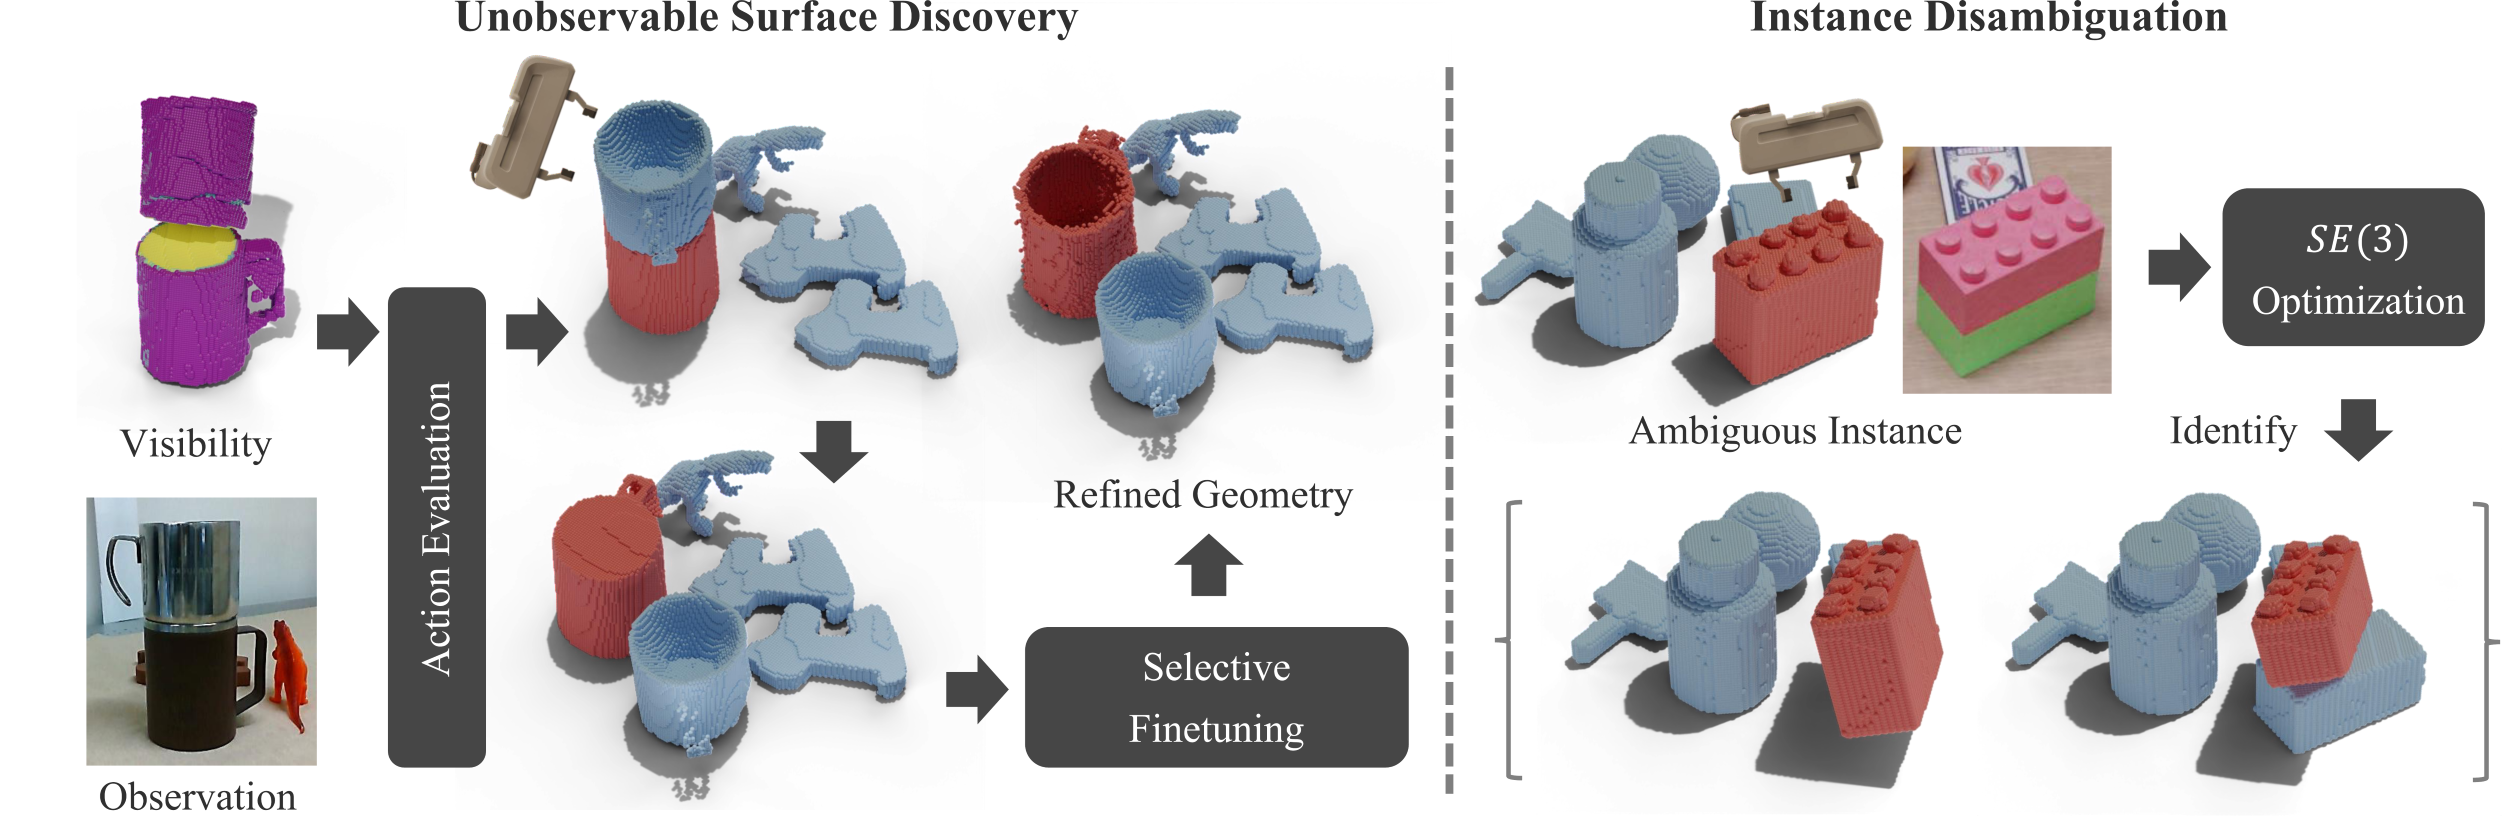 INGRID: Interactive Geometry and Instance Identification for Occluded ScenesComputers & Graphics, 2026
-
Zero-Shot Scene Geometry Recognition from Sparse Partial-View Images: Leveraging Generative Diffusion Models for Robotic Manipulation TasksIEEE Robotics and Automation Letters (RA-L), 2026
-
Point2Pose: Occlusion-Recovering 6D Pose Tracking and 3D Reconstruction for Multiple Unknown Objects Via 2D Point TrackersEuropean Conference on Computer Vision (ECCV), 2026
-
AnyCamVLA: Zero-Shot Camera Adaptation for Viewpoint Robust Vision-Language-Action ModelsIEEE International Conference on Intelligent Robots and Systems (IROS), 2026
-
-
High-Bandwidth Tactile-Reactive Control for Grasp AdjustmentInternational Conference on Robotics and Automation (ICRA), 2026
-
Hierarchical Reactive Grasping via Task-Space Velocity Fields and Joint-Space Quadratic ProgrammingInternational Conference on Robotics and Automation (ICRA), 2026
-
Differentiable Motion Manifold Primitives for Reactive Motion Generation under Kinodynamic ConstraintsInternational Conference on Robotics and Automation (ICRA), 2026
-
Point2Act: Efficient 3D Distillation of Multimodal LLMs for Zero-Shot Context-Aware GraspingInternational Conference on Robotics and Automation (ICRA), 2026
-
LEGO: Latent-space Exploration for Geometry-aware Optimization of Humanoid Kinematic DesignInternational Conference on Robotics and Automation (ICRA), 2026
2025
-
Behavior-Controllable Stable Dynamics Models on Riemannian Configuration ManifoldsIEEE Transactions on Robotics (T-RO), 2025
-
ScrewSplat: An End-to-End Method for Articulated Object RecognitionConference on Robot Learning (CoRL), 2025
-
Motion Manifold Flow Primitives for Task-Conditioned Trajectory Generation under Complex Task-Motion DependenciesIEEE Robotics and Automation Letters (RA-L), 2025
-
Isometric Regularization for Manifolds of Functional DataInternational Conference on Learning Representations (ICLR), 2025
-
Diverse Policy Learning via Random Obstacle Deployment for Zero-Shot AdaptationIEEE Robotics and Automation Letters (RA-L), 2025
2024
-
T2SQNet: A Recognition Model for Manipulating Partially Observed Transparent Tableware ObjectsConference on Robot Learning (CoRL), 2024
-
EquiGraspFlow: SE(3)-Equivariant 6-DoF Grasp Pose Generative FlowsConference on Robot Learning (CoRL), 2024
-
MMP++: Motion Manifold Primitives with Parametric Curve ModelsIEEE Transactions on Robotics (T-RO), 2024
-
Graph Geometry-Preserving AutoencodersInternational Conference on Machine Learning (ICML), 2024
2023
-
NFL: Normal Field Learning for 6-DoF Grasping of Transparent ObjectsIEEE Robotics and Automation Letters (RA-L), 2023
-
-
Equivariant Motion Manifold PrimitivesConference on Robot Learning (CoRL), 2023
-
Leveraging 3D Reconstruction for Mechanical Search on Cluttered ShelvesConference on Robot Learning (CoRL), 2023Code·Video·Poster·OpenReview
-
On Explicit Curvature Regularization in Deep Generative ModelsTAG-ML Workshop, ICML 2023
-
Geometrically Regularized Autoencoders for Non-Euclidean DataInternational Conference on Learning Representations (ICLR), 2023PDF·Poster·OpenReview
-
Geometric Methods for Manifold Representation LearningPh.D. Thesis, Seoul National UniversityPDF·Abstract·Slides
2022
-
SE(2)-Equivariant Pushing Dynamics Models for Tabletop Object ManipulationsConference on Robot Learning (CoRL), 2022 (oral, 6.5%)Proceedings·Code·OpenReview
-
DSQNet: A Deformable Model-Based Supervised Learning Algorithm for Grasping Unknown Occluded ObjectsIEEE Transactions on Automation Science and Engineering (T-ASE), 2022
-
A Statistical Manifold Framework for Point Cloud DataInternational Conference on Machine Learning (ICML), 2022
-
Regularized Autoencoders for Isometric Representation LearningInternational Conference on Learning Representations (ICLR), 2022PDF·Code·Video·Slides·Poster·OpenReview
2021
-
Neighborhood Reconstructing AutoencodersConference on Neural Information Processing Systems (NeurIPS), 2021
-
IMAT: The Iterative Medial Axis TransformComputer Graphics Forum, 2021PDF·Article